University of Newcastle coursework
Warman Design & Build
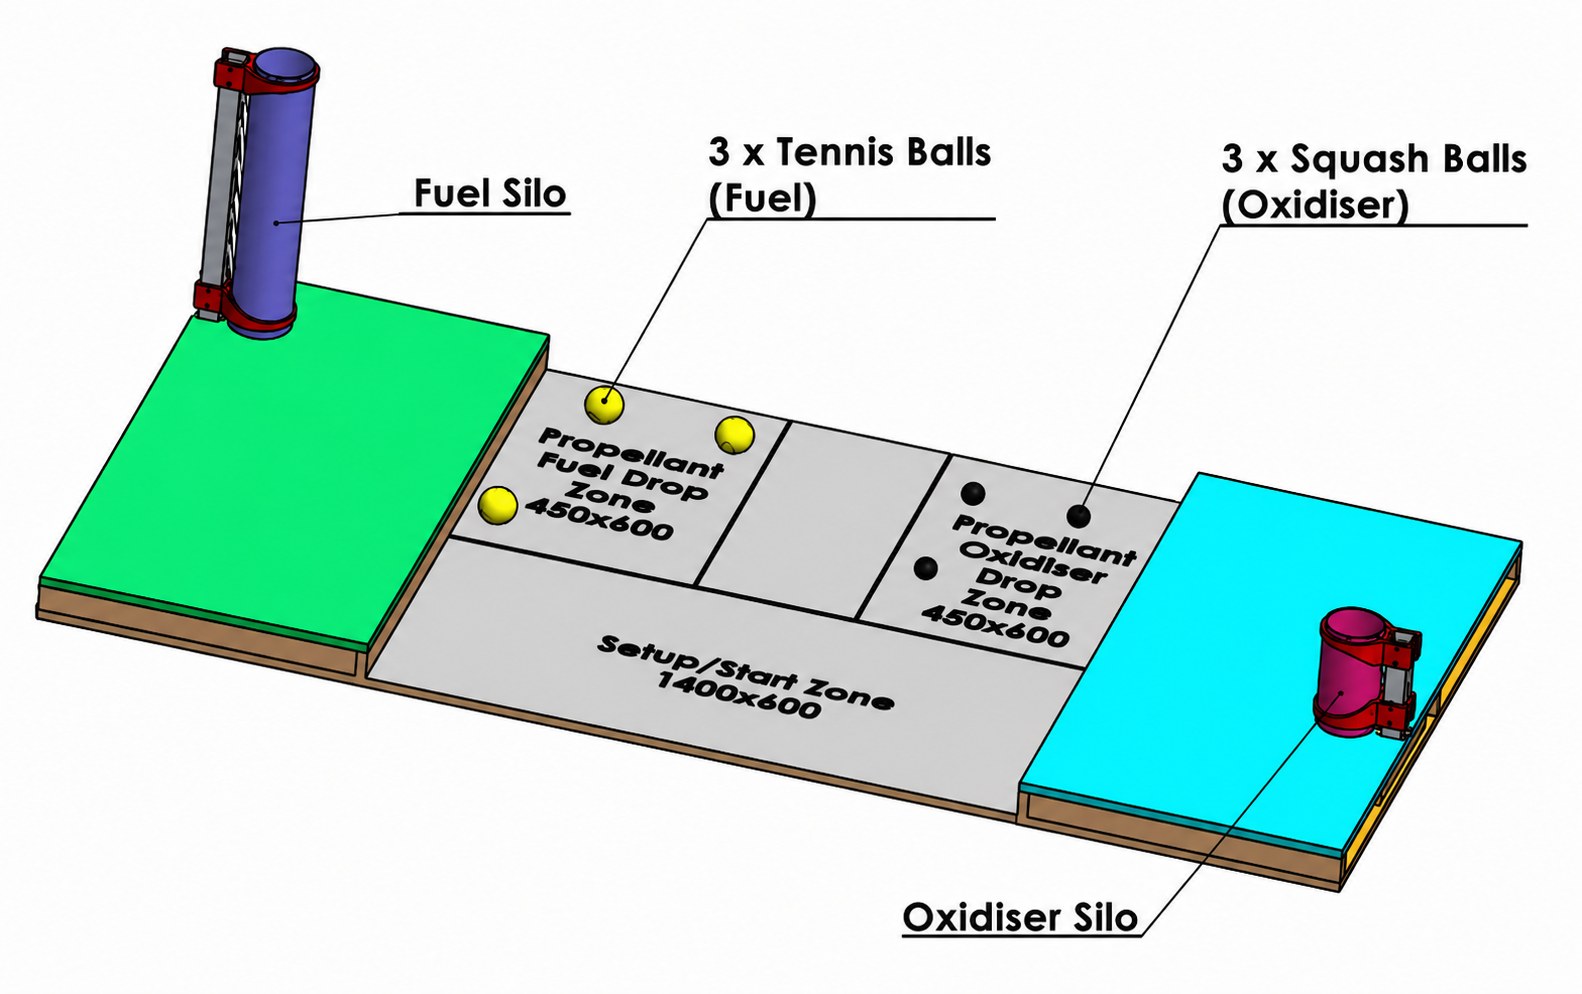
Designed, built, and demonstrated a scale prototype of an autonomous system for handling fuel and oxidiser vessels and depositing each in its matching silo, constrained to a 400 × 400 × 400 mm volume and a mass of 6 kg.
What I did
- Took ownership of mechanical design and fabrication, converting the team’s initial concept into a fully functional crane.
- Modelled each mechanical component and assembly in Fusion, resolving interfaces and fits.
- 3D-printed non-standard PETG parts, machined the rails, and assembled the crane.
- Tested the mechanical subsystem and assisted with electrical and final integration testing.
Decisions that mattered
A 1.33 mm window
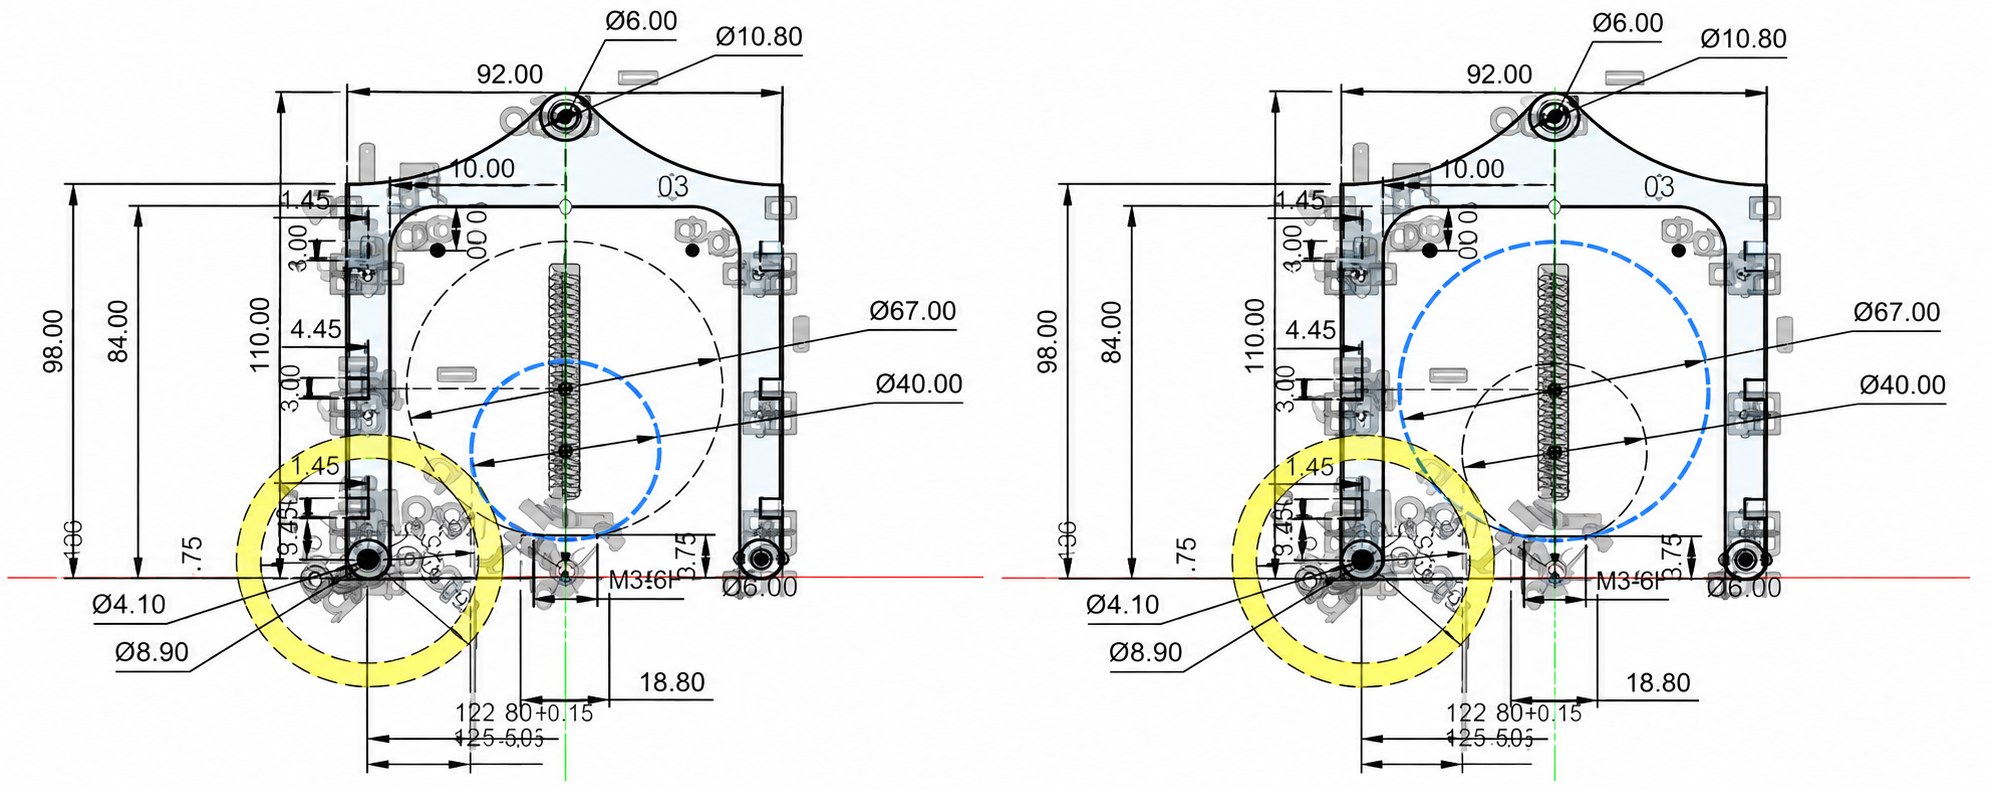
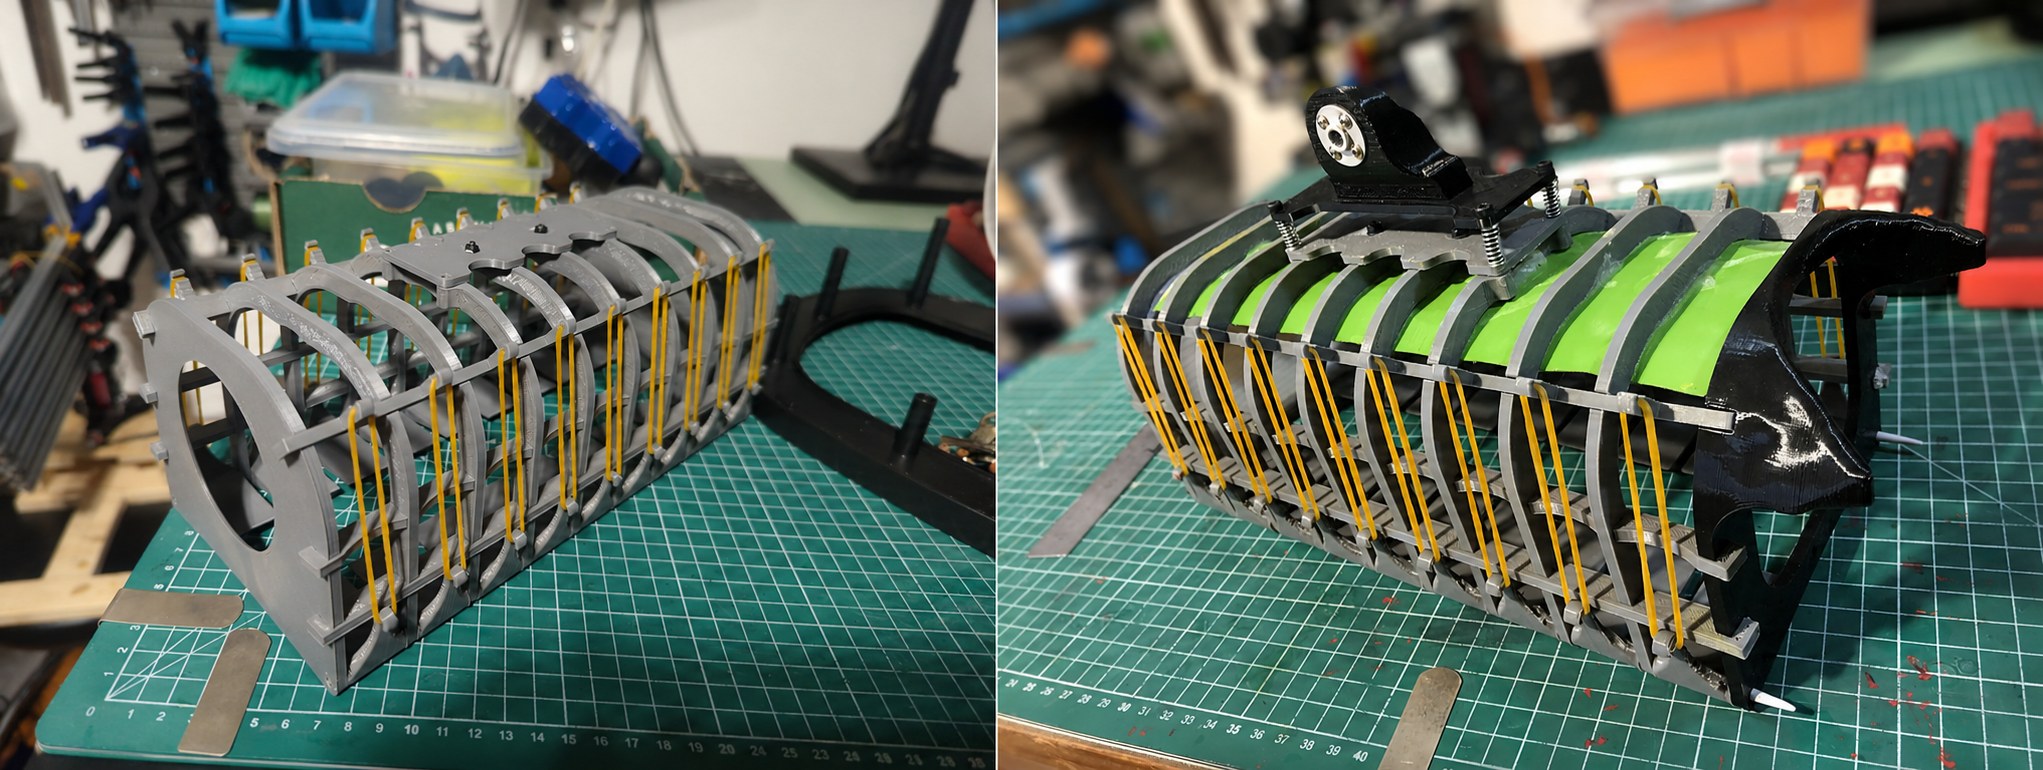
One toolhead had to lift balls of two sizes: 67 mm tennis balls and 40 mm squash balls. The combs rode up over a ball and dropped closed behind it.
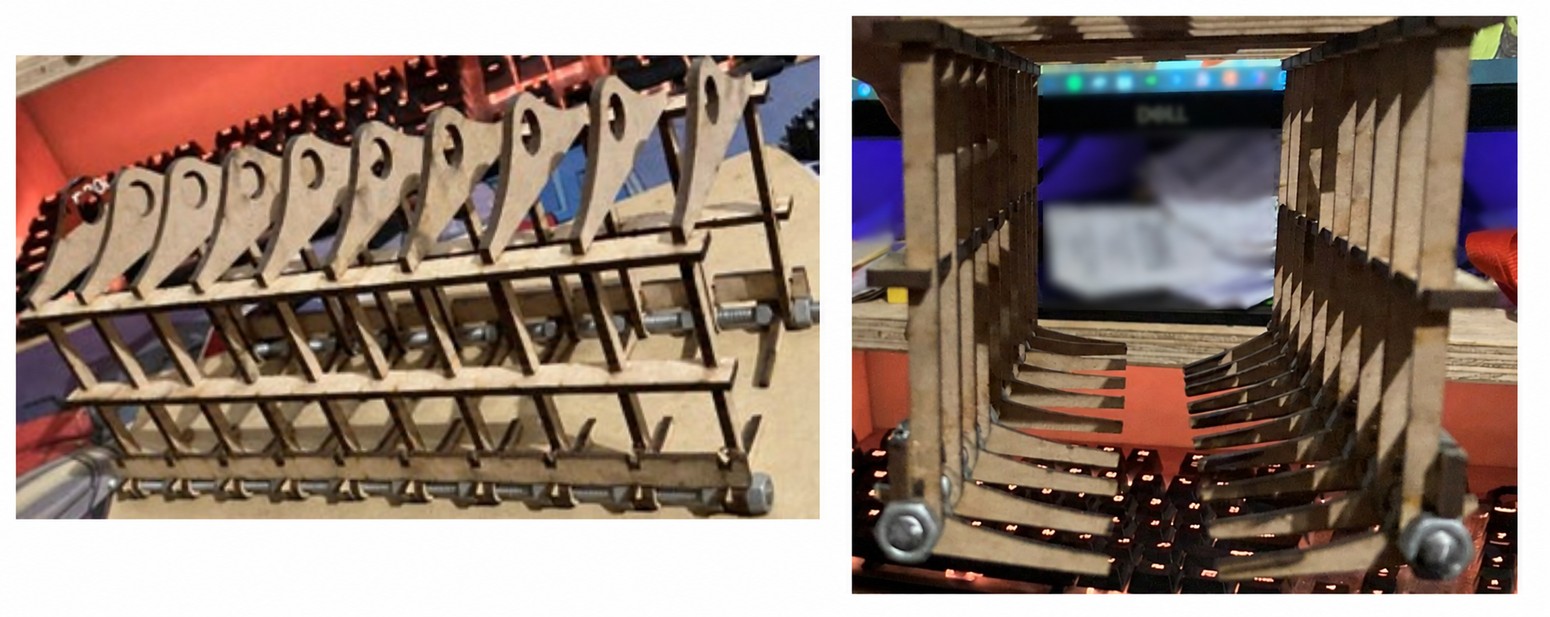
That only worked inside a 1.33 mm band of comb-tip length. Longer, and it stopped the tennis ball going in; shorter, and the squash ball dropped straight back out. The first toolhead was laser-cut and iterated by eye, and worked poorly.
When I took over design and fabrication:
- Calculated the correct comb length and achieved a working geometry in one 3D-printed iteration.
- Changed to a rubber-band-loaded comb because the previous passive combs jammed.
- Redesigned the toolhead in PETG with hollow infill, halving its initial mass.
Accuracy against mass
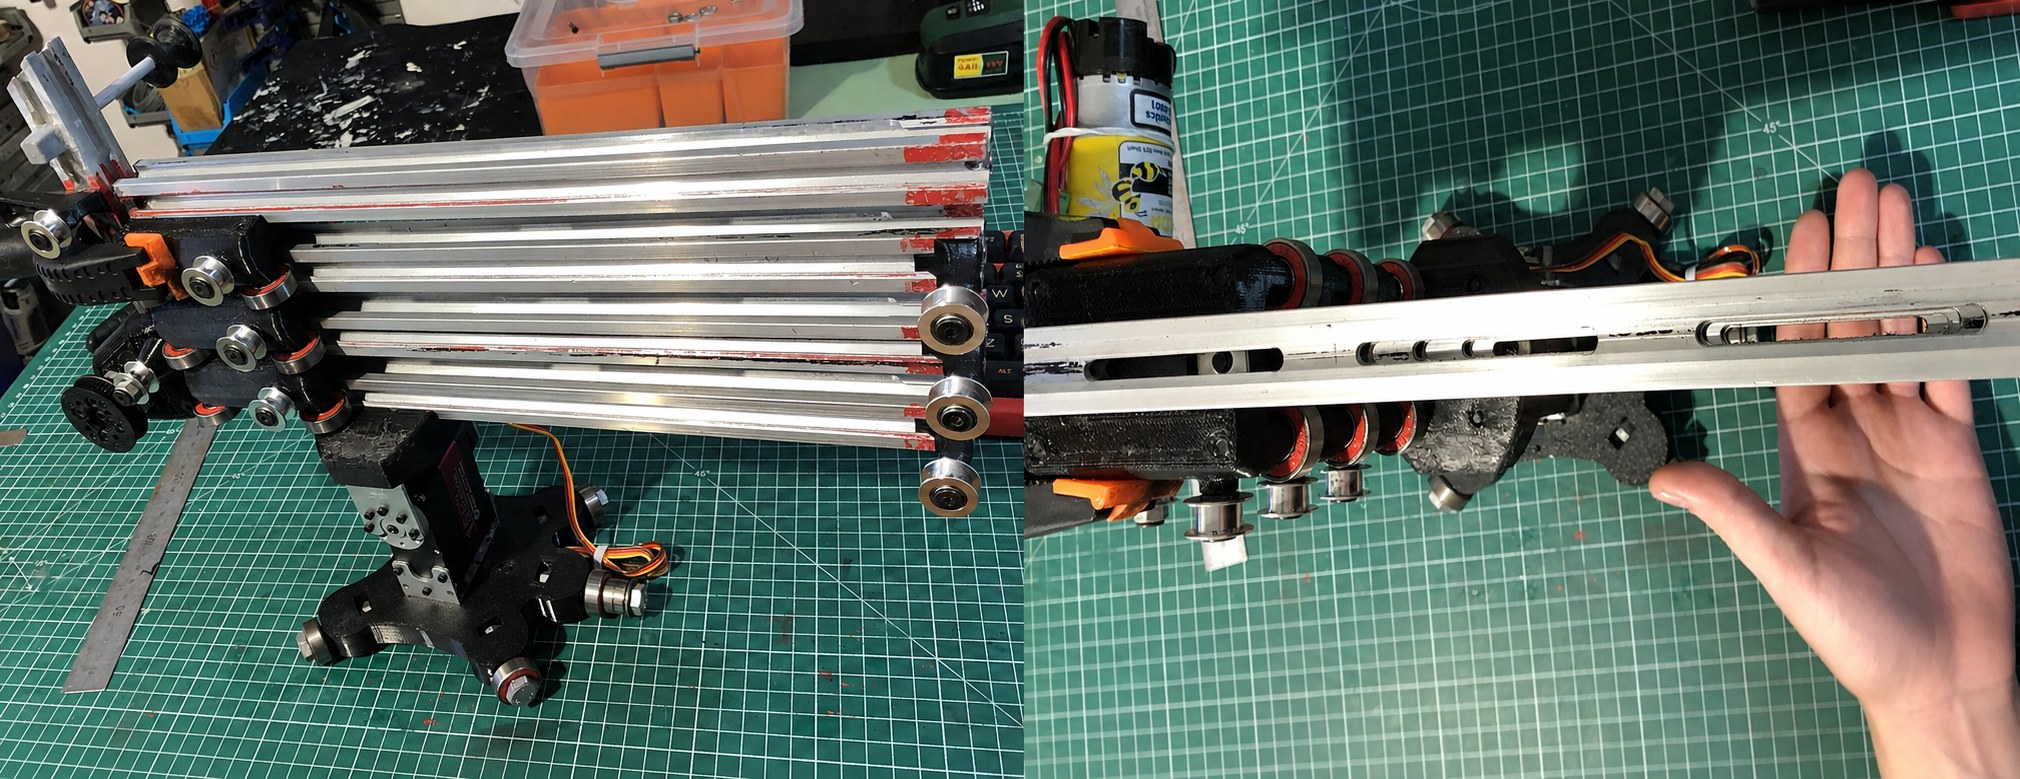
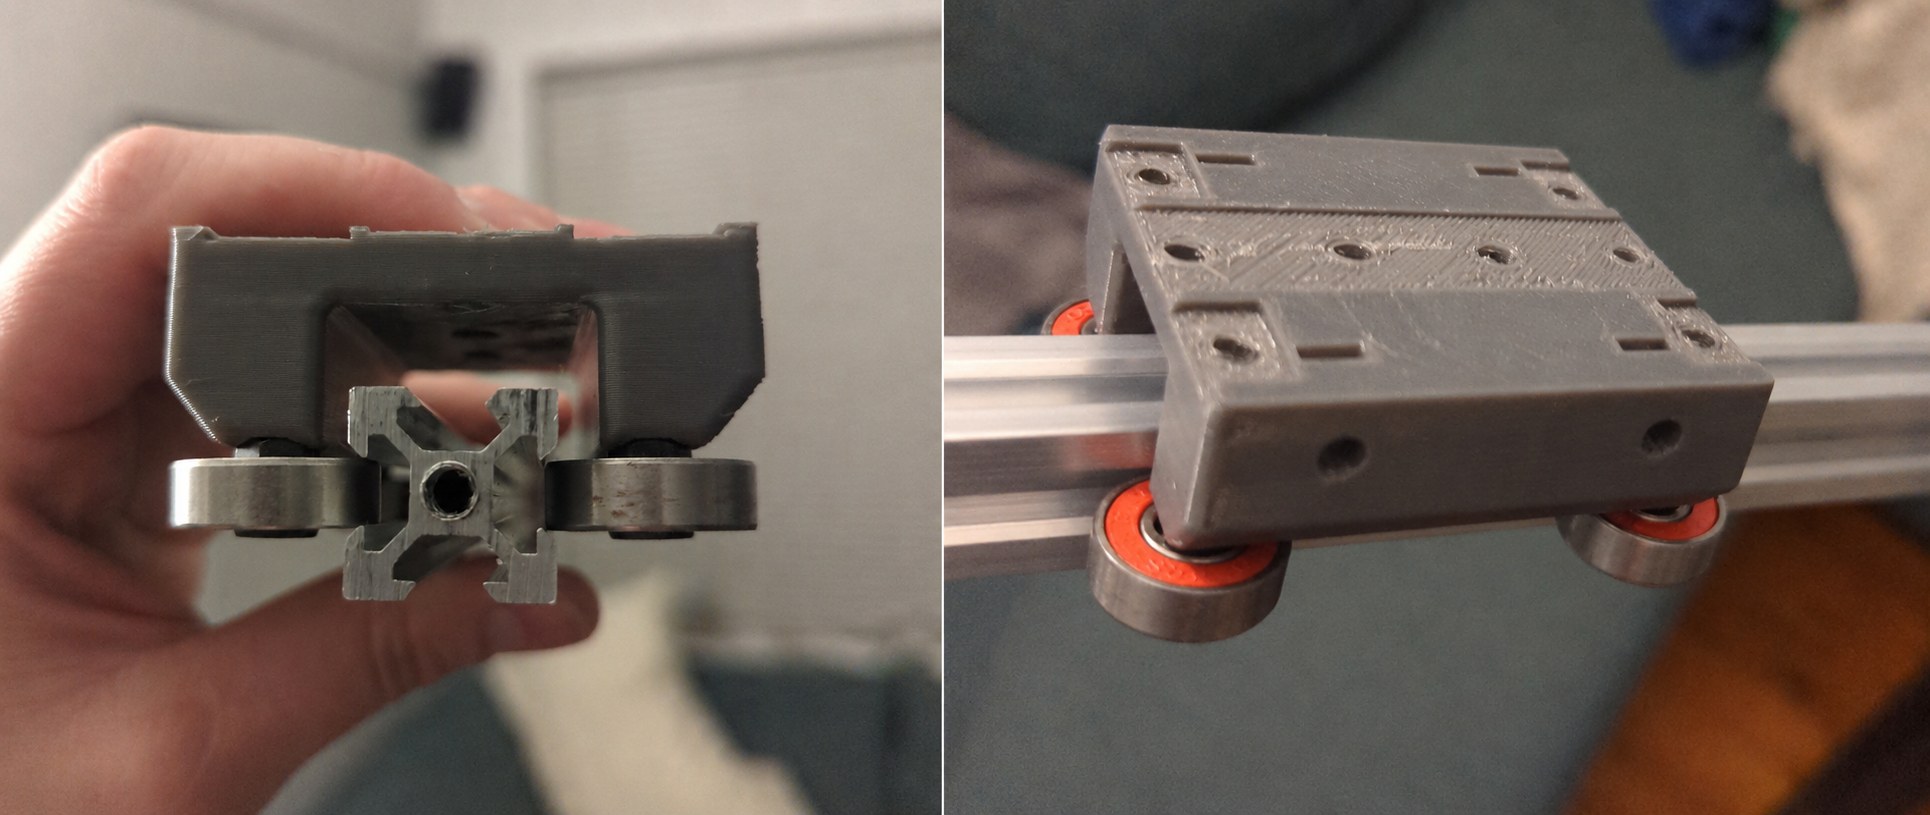
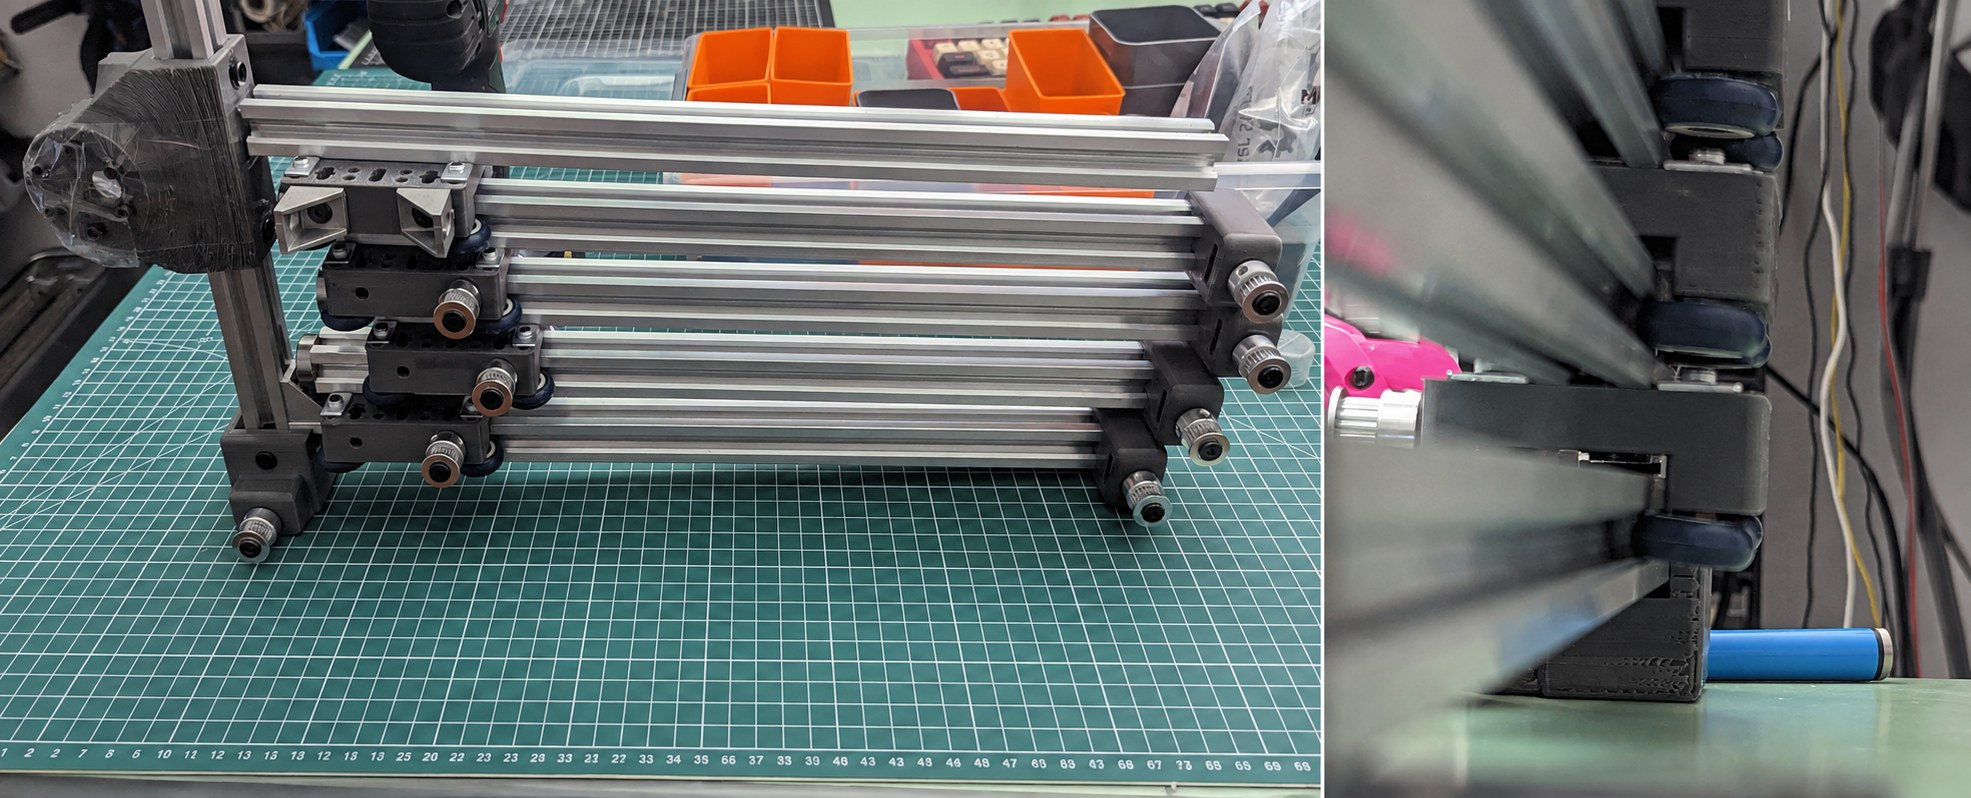
Gantry v1 ran on rubberised wheels, and the rails deflected under the expected load, which affected accuracy. Swapping to bearings fixed it but added mass to all rails.
I took the trade-off and recovered the added mass by tightening the bearing-to-rail tolerance, redesigning the gantry carriages, and machining slots in the rails.
Smooth operator
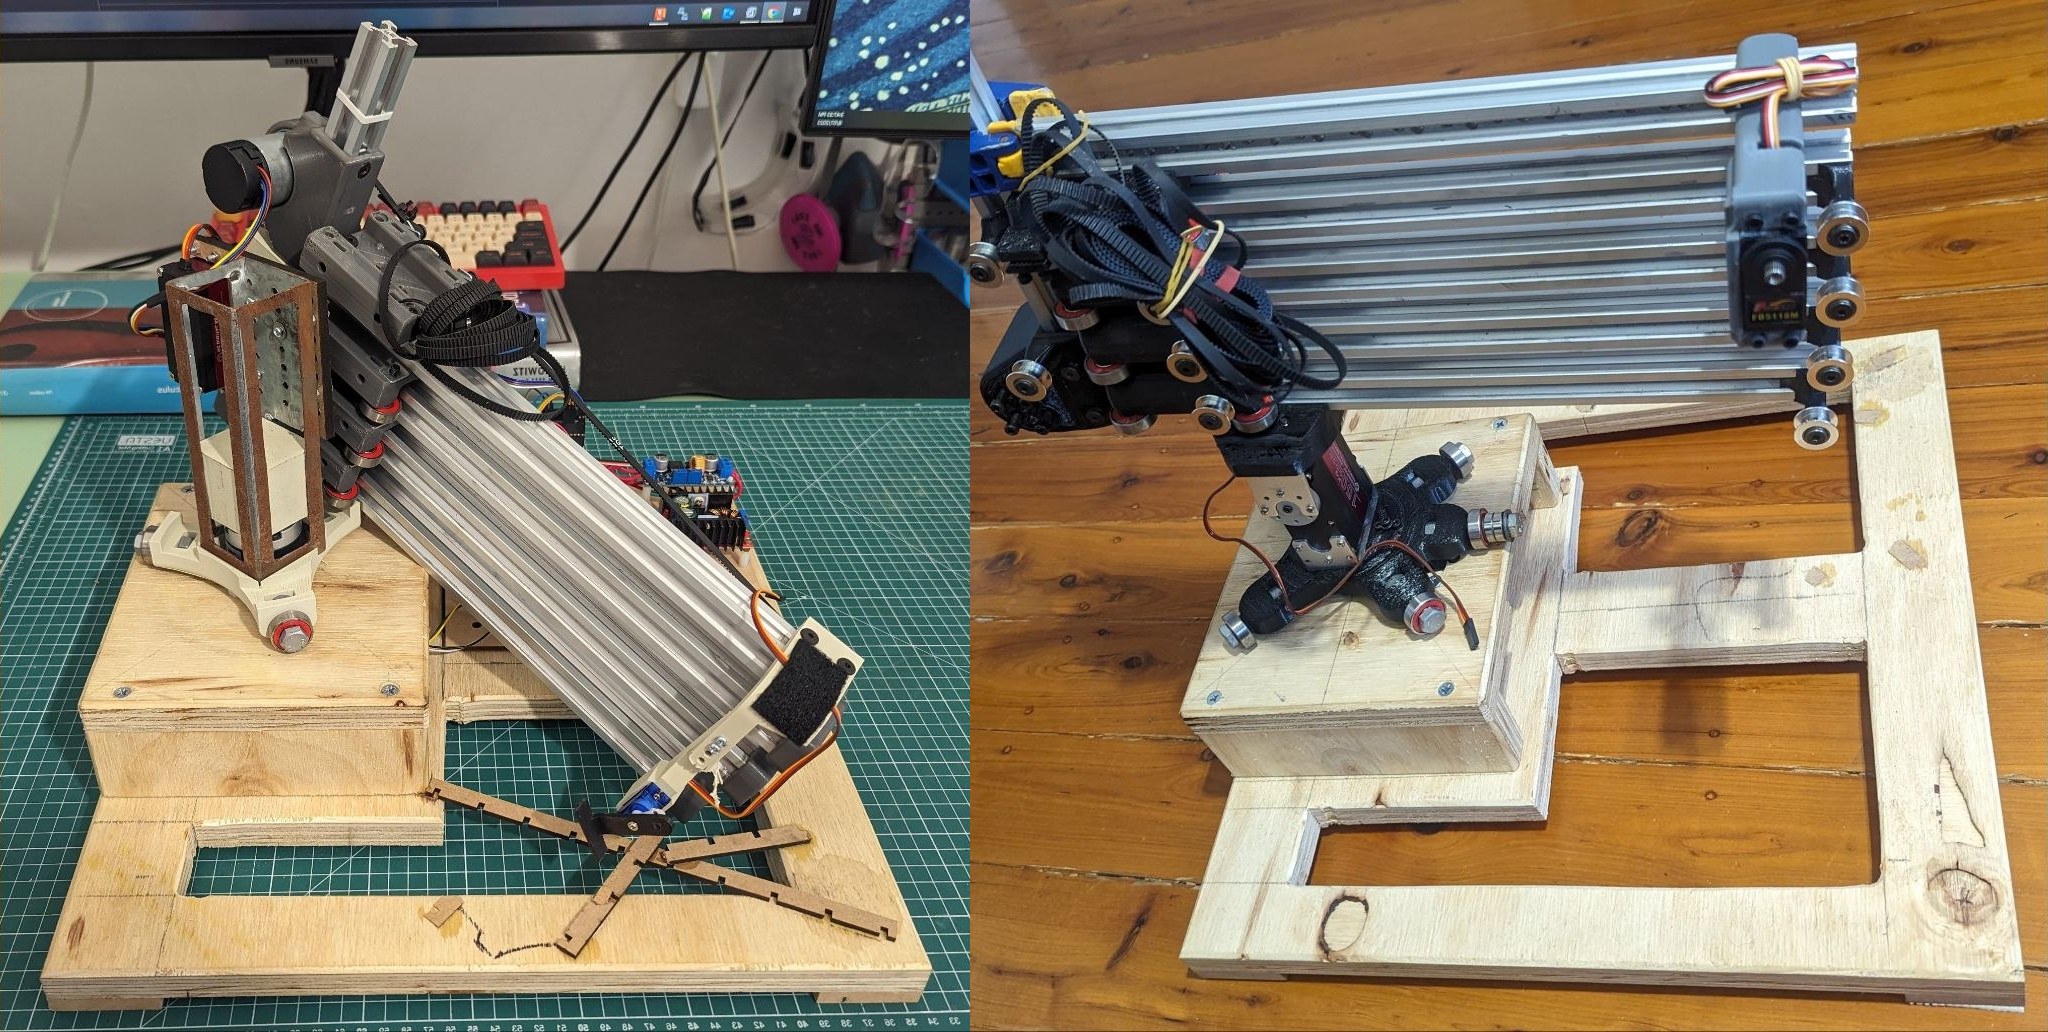
The central column of v1 and v2 combined a steel tube, a high-mounted servo for an off-centre vertical pivot, and a horizontal pivot platform with its mass distributed across three bearings. All printed parts were in PLA.
When I took over:
- Replaced all PLA-printed parts with PETG.
- Reduced overall mass by replacing the steel tube with a single centrally mounted servo.
- Fully redesigned the horizontal pivot platform with a five-bearing base, the bearings placed where the torque peaked during operation.
Model


What I’d change
Subsystem masses were first estimated from the components expected to survive prototyping, but fixes during testing added mass that was not accounted for. A mass budget updated at every design change would have caught those problems earlier.
Communication between team members would have been better with a project manager tracking accountability, capacity, and timelines.